( 01 )
Cameras see motion, not force.
Seating a connector, routing a cable or clipping a harness depends on forces no camera records.
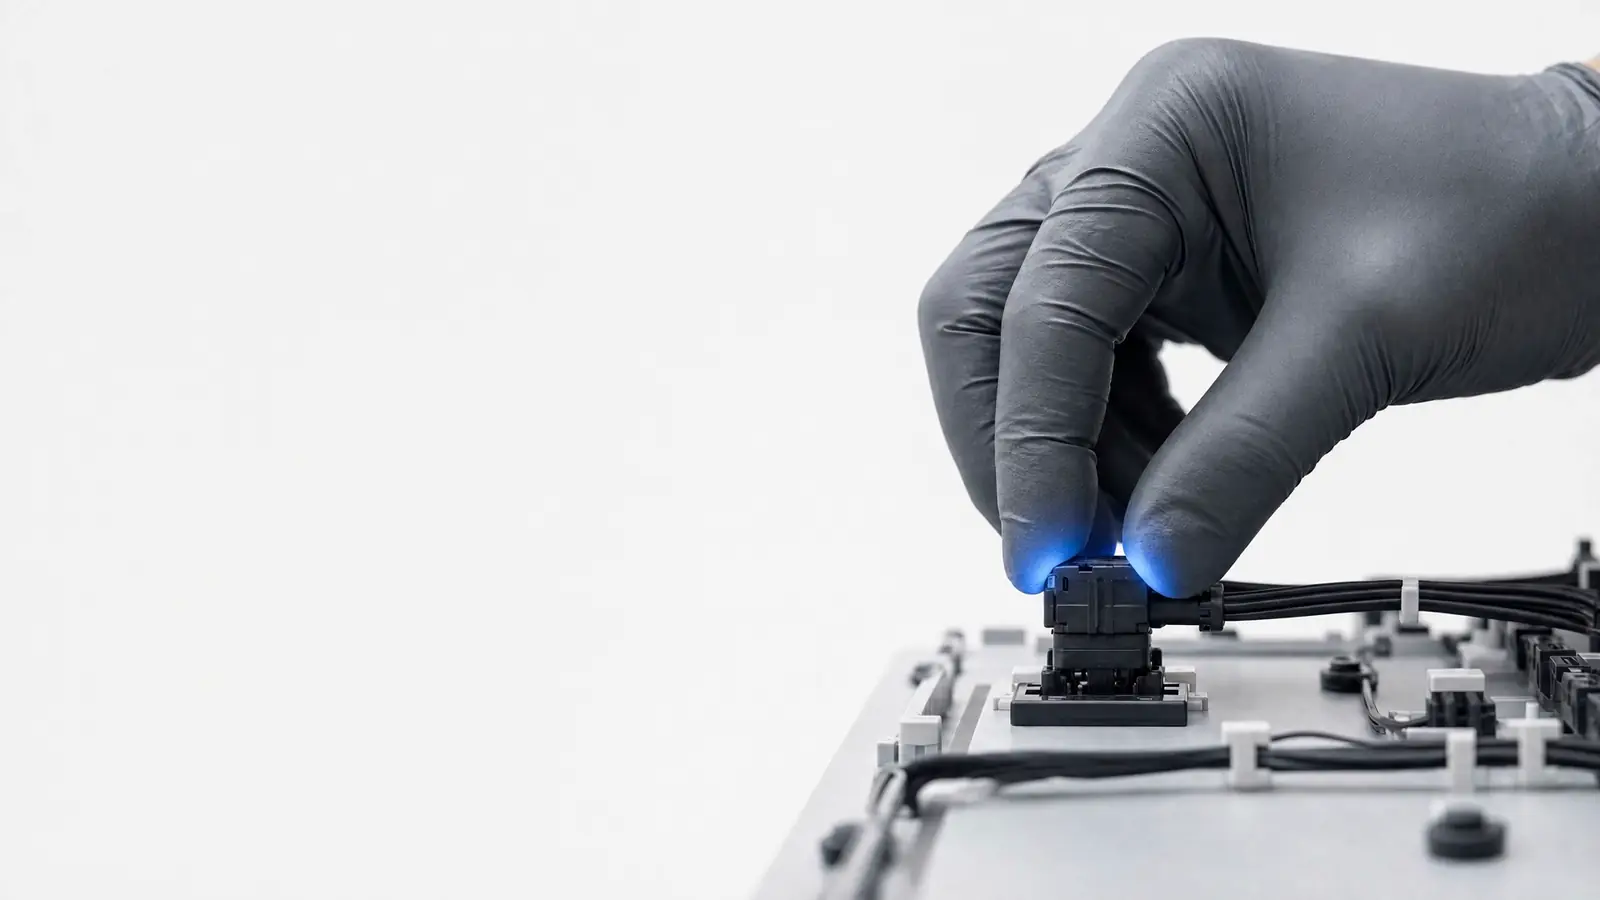
FIG.01 Tactile data for robots
Taktil captures how skilled hands feel, move and see during real industrial work, and turns it into training data for robots.
Robot shown for illustration. Taktil does not build robots.
( 01 )
Seating a connector, routing a cable or clipping a harness depends on forces no camera records.
( 02 )
Real production brings the variance, mistakes and recoveries robots meet on the line.
( 03 )
Buyers need to know where data came from, who agreed to it, and how it was documented.
Six assembly tasks where automation depends on what fingers feel, from wire harness assembly to control cabinet wiring.
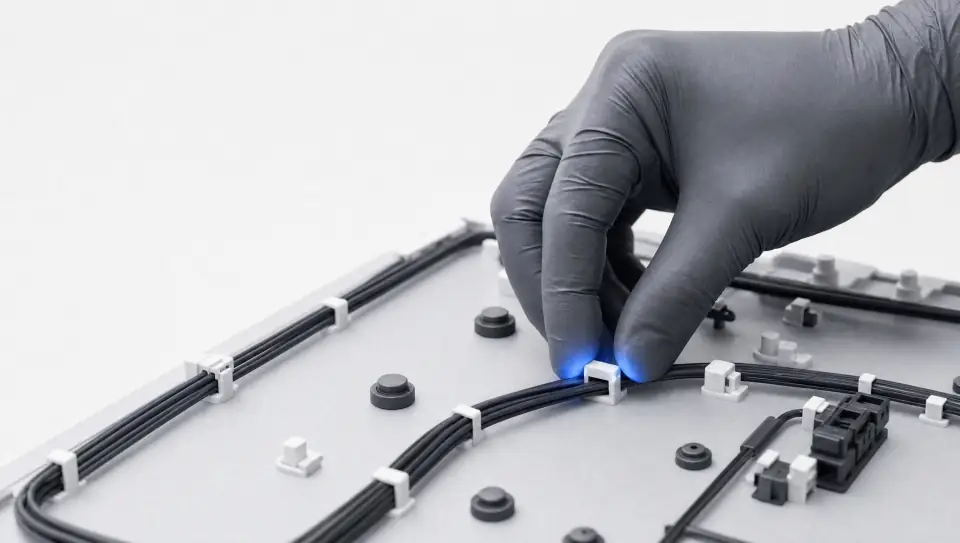
A.01
Routing, clipping and taping flexible cables, where grip force and feel matter more than sight.
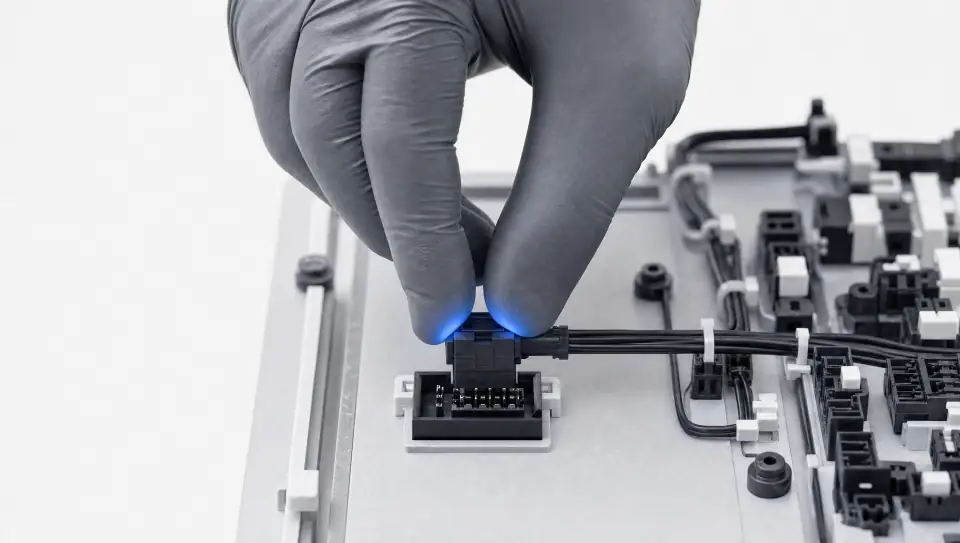
A.02
The push, the click, the check. The moment of success lives in a force signal, not in pixels.
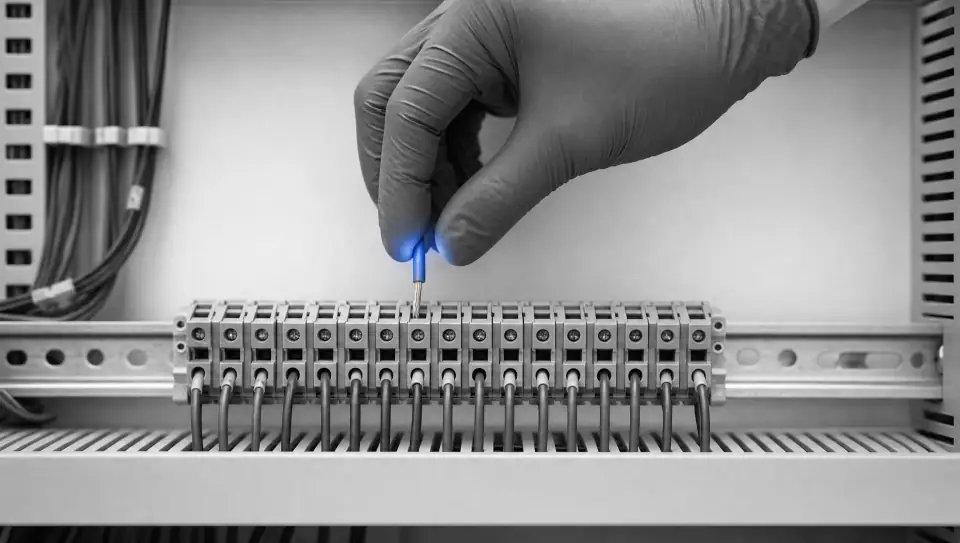
A.03
Stripping, inserting and fastening wires in tight spaces, with precise finger control.
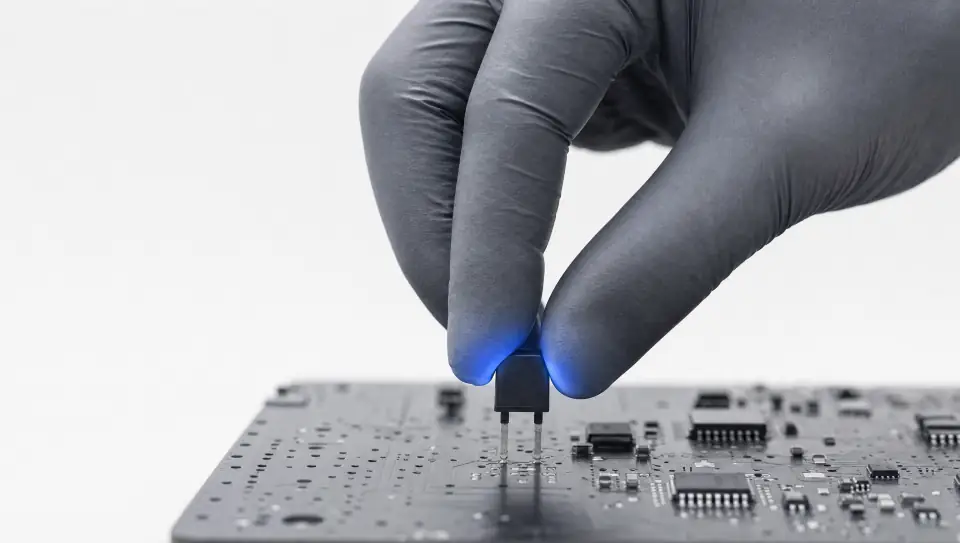
A.04
Inserting components, fitting clips, handling delicate parts without damage.
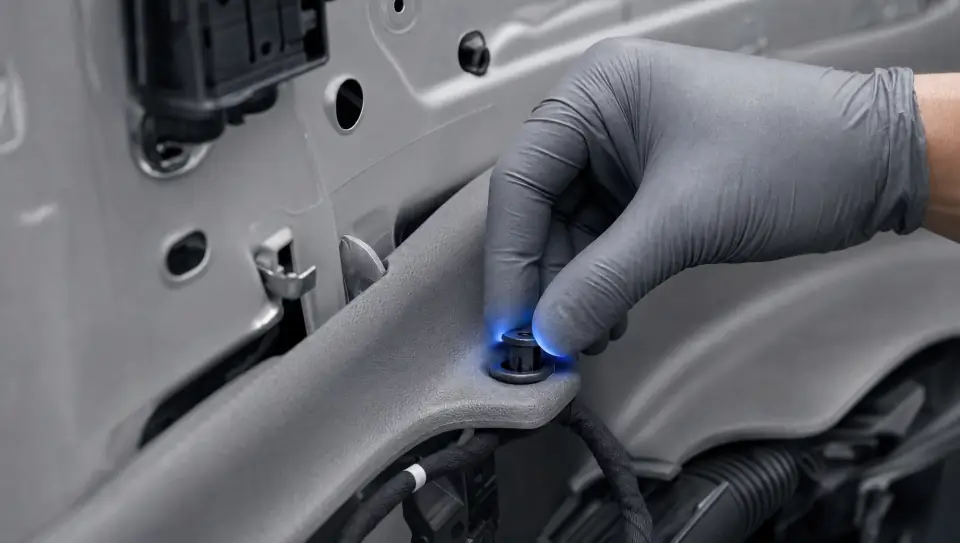
A.05
Clips, hoses and trim, fitted by feel inside cramped vehicle interiors.
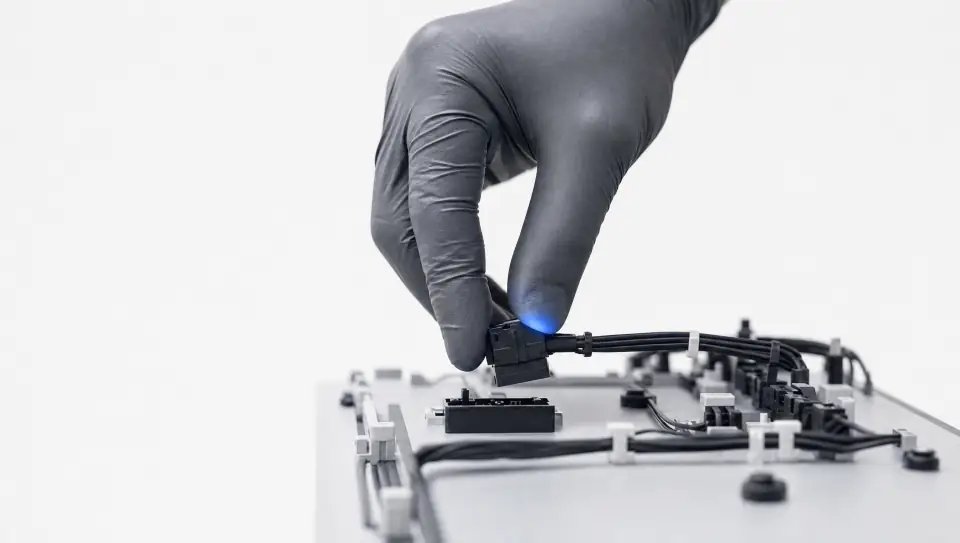
A.06
Missed clicks, stuck parts, second attempts. The data robots need to fail safely and try again.
Delivered in standard formats for robot learning.
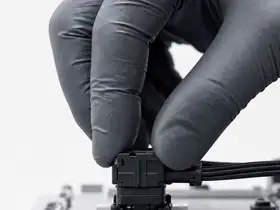
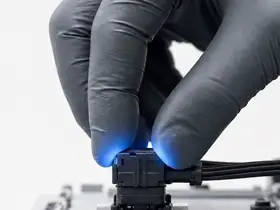
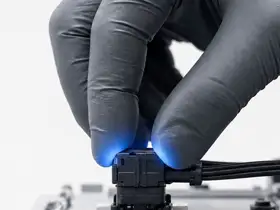
Skilled workers volunteer to wear our capture kit during normal production.
Every task is recorded with touch, motion and vision, without slowing the line.
Quality-checked, documented and licensed to robot makers and model teams.
We are onboarding our first partner plants in Europe and Latin America. Partners receive a share of the value their data creates, their own copy of the data, and an automation study for their line.
Become a partner plantNo. We are independent and supply data to robot makers and model teams.
Yes. We scope capture programs around your tasks and your hardware.
We license data. Exclusivity windows are available.
No. Data is never used to assess individual performance.
Taktil / FAQ
Quick answers
Hi. Tap a question and the answer appears right away. For anything else, write to us directly.