Dataset Contact-rich manipulation
Contact-rich manipulation data, measured at the moment of contact.
Some tasks succeed or fail on touch: a connector clicks home or it does not, a cable sits in its clip or slips back out. A dataset for these tasks has to measure the contact. Video alone does not show it.
Where the camera runs out.
Robotics calls a task contact-rich when hand and workpiece stay in contact for a while and forces decide the outcome. Almost all assembly work qualifies: mating connectors, pressing wires into holders, setting clips, inserting components.
A camera sees the hand move. It does not see how hard the hand presses or the instant the part gives way. That is exactly what a robot has to learn to take over the same task.
What belongs in the dataset.
All streams run in sync, so the force peak, the finger pose and the video frame belong to the same instant.
- 01Tactile and force signals at the fingertipsThey show when a part gives way, clicks into place or jams.
- 02Full hand and finger poseThe pose of every finger over time, so a model learns grip and force together instead of separately.
- 03First-person and wrist videoThe view from above shows the workstation, the view from the wrist shows what the fingers themselves hide.
- 04Action labels, time-aligned and quality-checkedReach, grasp, insert, seat, release. Teams find the exact moments they need for training.
- 05Failures and second attemptsA missed click or a stuck part is part of real work. Live production supplies these moments on its own.
A data glove instead of teleoperation.
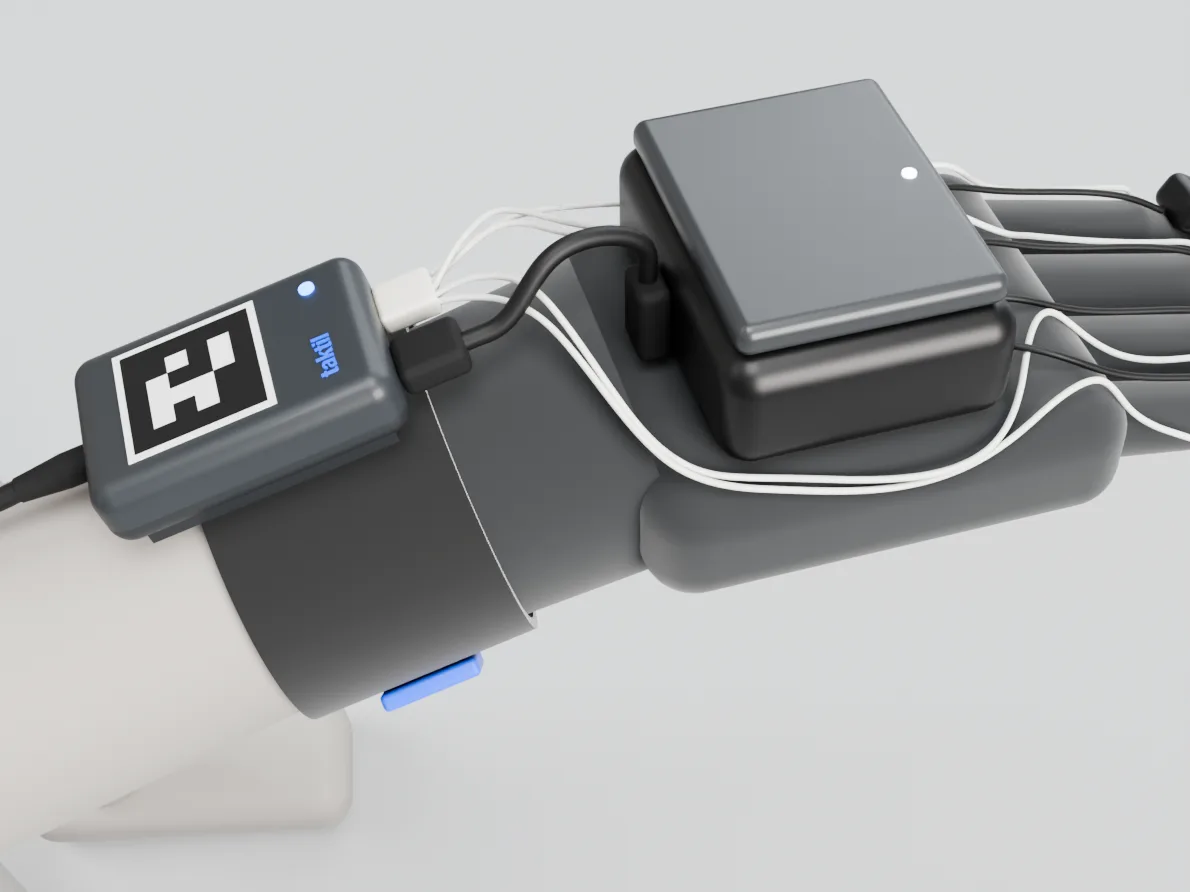
Many robot manipulation datasets come from teleoperation: a person steers a robot arm and usually cannot feel what the gripper touches. Taktil records the hand itself.
Skilled workers wear a capture kit with gloves, cameras on wrist and head and a small unit on the belt. They keep working at their usual pace, and the model learns from hands that do the task every day.
Delivered in standard formats.
The data comes in standard formats for robot learning that teams can load straight into training. Many teams work with LeRobot, the open robotics dataset library from Hugging Face. Force and tactile signals fit in there as their own stream next to the camera frames.
If you need specific tasks, we scope capture programs around your tasks and your hardware. Why industrial robots need this kind of data is on the page Physical AI training data.
More on training data from assembly work.
Tell us which tasks your robot should learn.
Taktil does not build robots. We supply data to robot makers and AI model teams. We license data. Exclusivity windows are available.
Talk to us